P-05 of P-05
Pebble
Quadruped robot · code-driven CAD
Pebble is a small four-legged robot whose entire design is written in code: a fully parametric model in a code-CAD environment, regenerated by changing a handful of parameters, exported for fabrication, and built into hardware that walks.
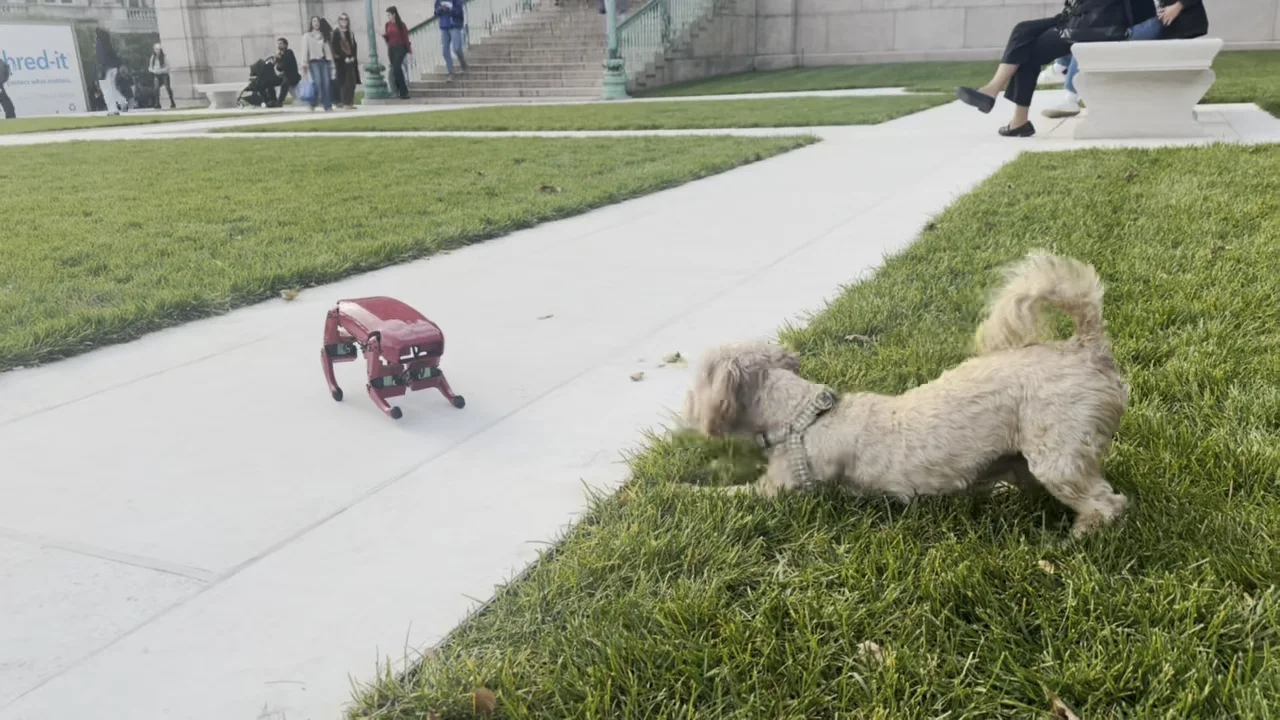
Section A-A, Meet Pebble
A quadruped robot, out for a walk
Pebble is a compact quadruped robot I designed and built. Out on a walk, it meets a real dog, who is not quite sure what to make of it.
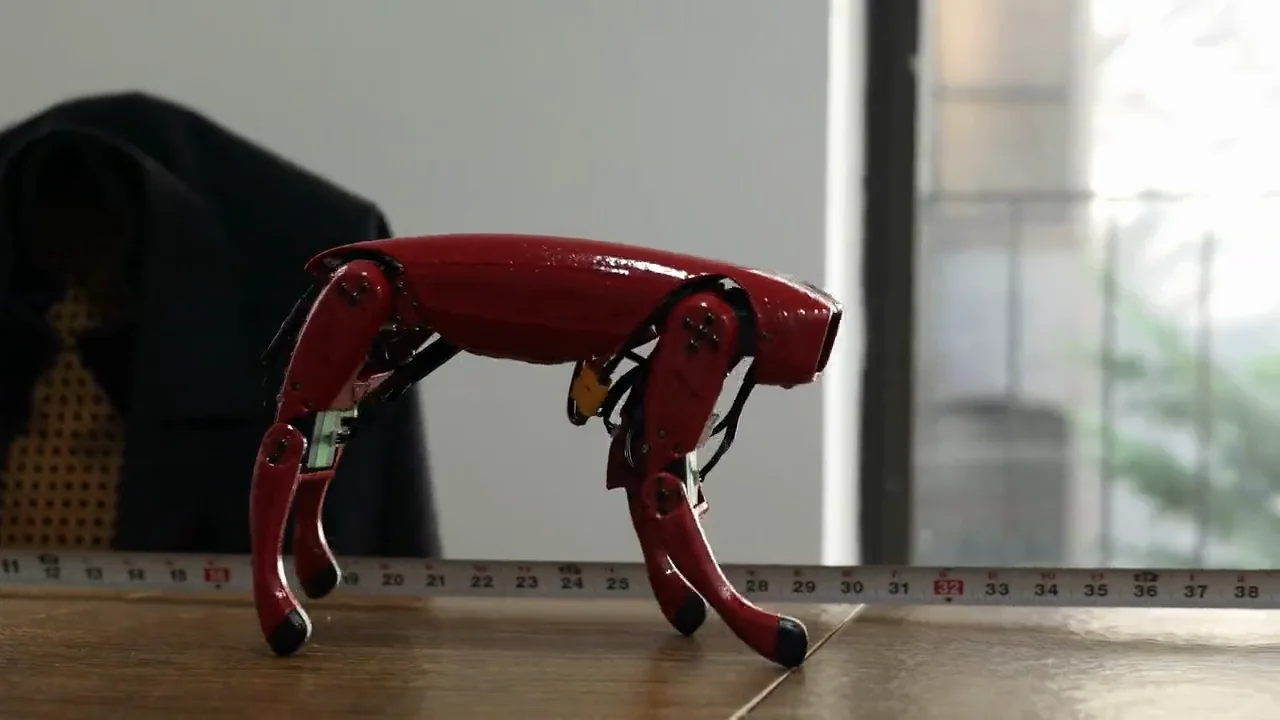
Section B-B, On the move
Walking on its own four legs
A side-on view of Pebble trotting across a tabletop, with a tape measure alongside for scale.
Section C-C, Gait testing
Legs first, ground later
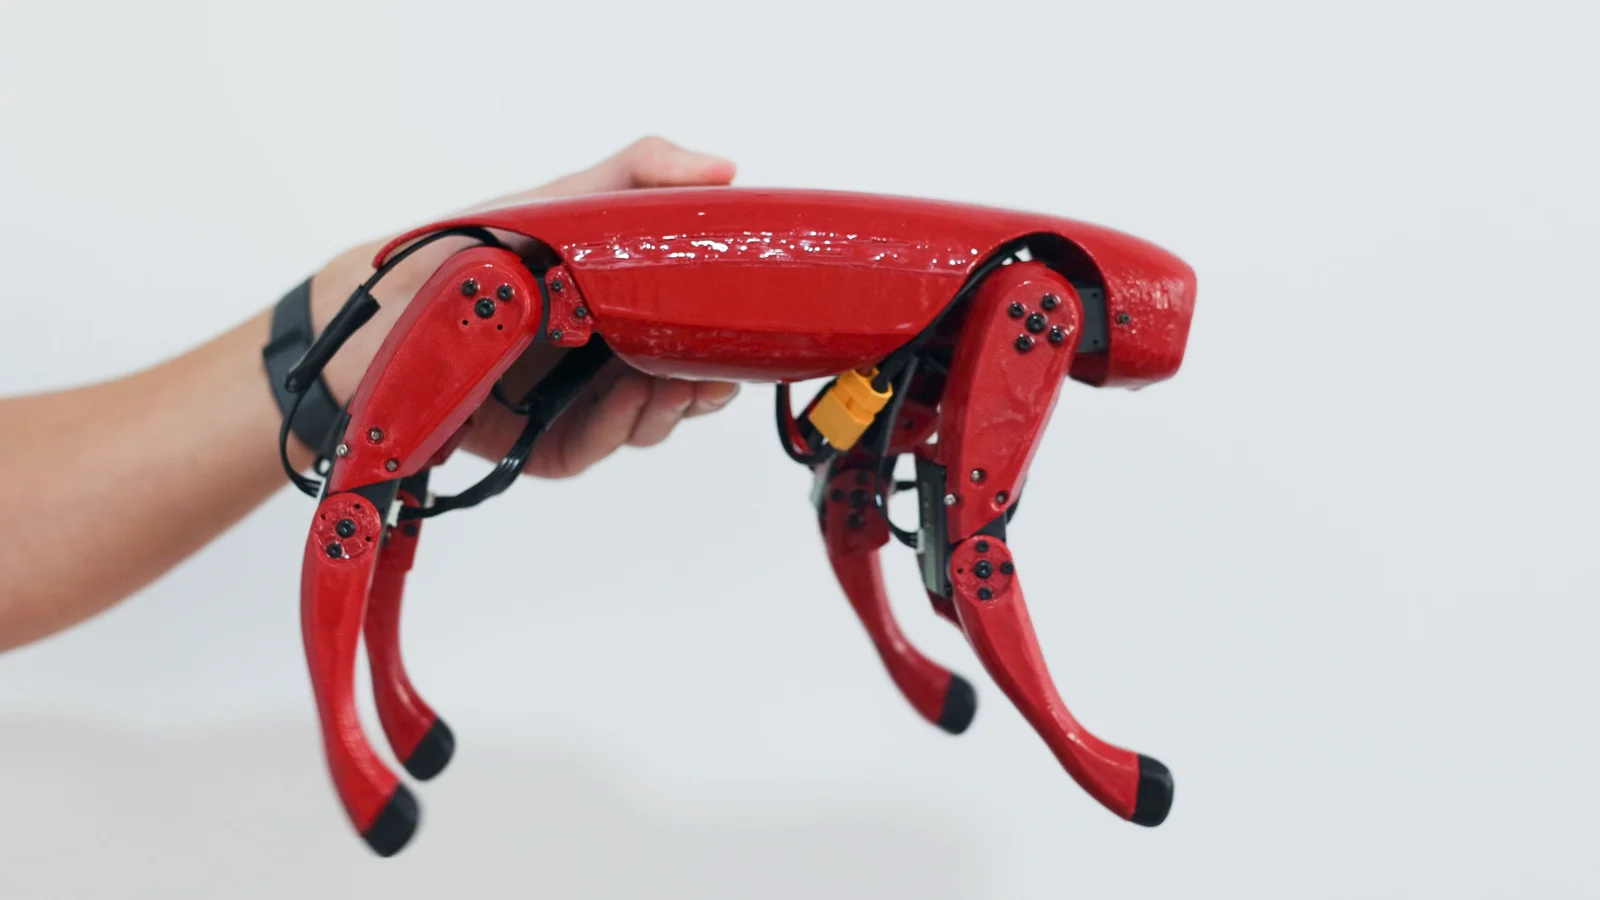
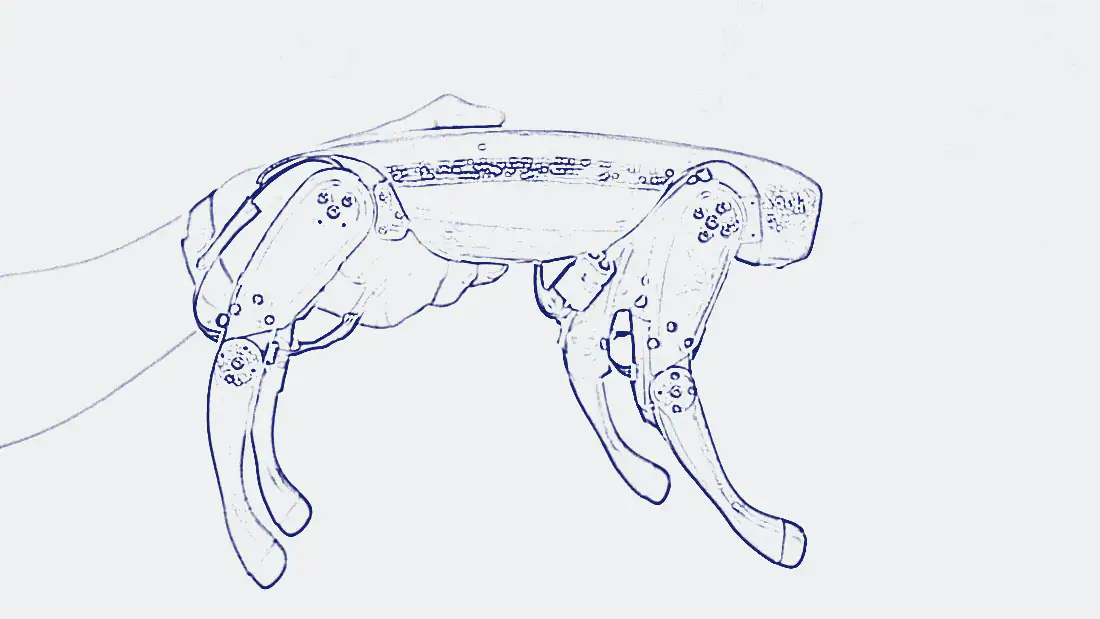
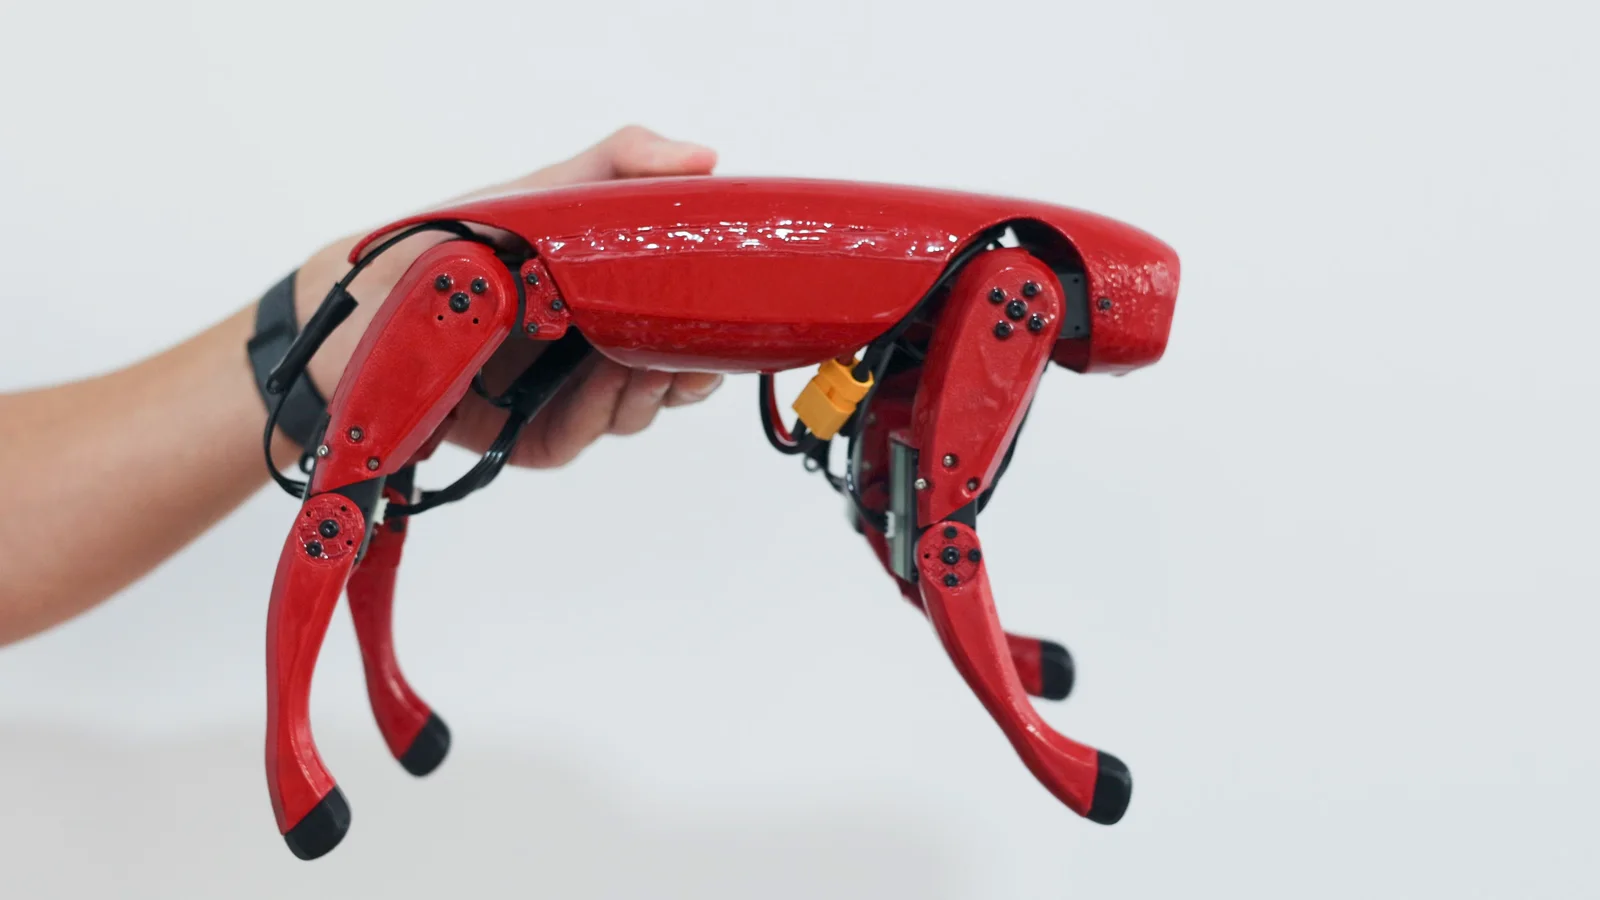
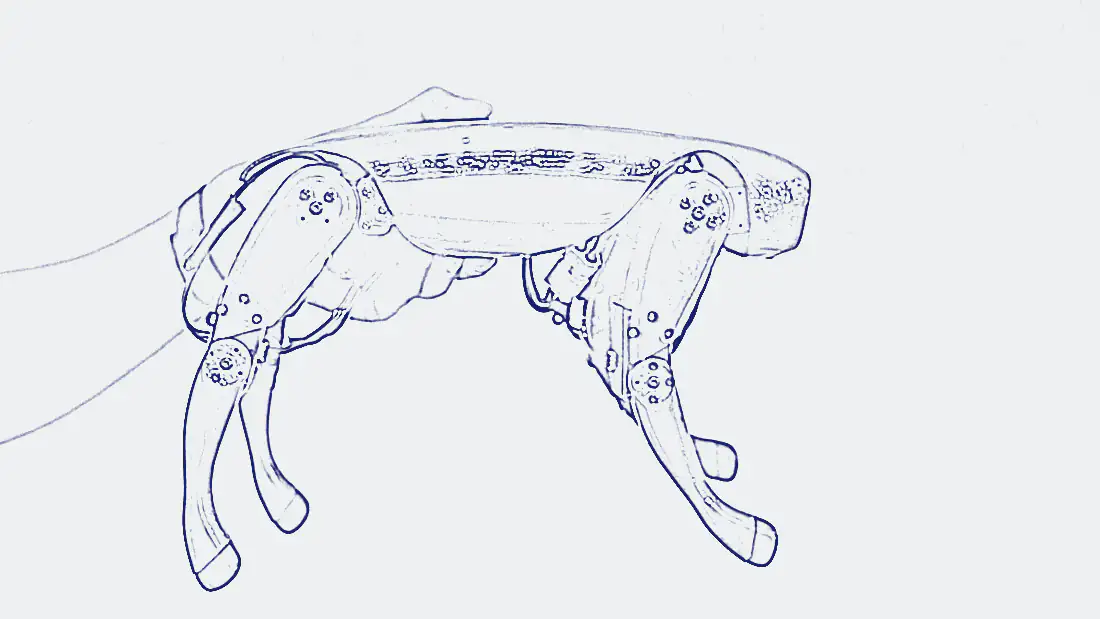
Gaits are tested with the body held in hand and the legs off the ground, so the motion of every joint can be checked before the legs take the robot's weight.
Section D-D, Written in code
Geometry as relationships
The whole robot is defined in Python inside a parametric code-CAD environment (agentcad and build123d), described by relationships and dimensions rather than fixed, hand-drawn sketches.
Iterate and build
Iterate by parameter, export to fabricate
Proportions, joint placement, and part counts regenerate from a handful of parameters, which makes design iterations fast to explore. The model exports to multiple formats for downstream fabrication and simulation.